DP / PATEL
All Projects

Team Capstone Project — Robotics & Mechatronics

Autonomous Delivery and Retrieval Rover

A team-built 4WD skid-steer rover for autonomous package delivery and retrieval, integrating ToF and IMU sensing with staged failure analysis.
RoboticsEmbeddedSensor FusionControl SystemsValidation
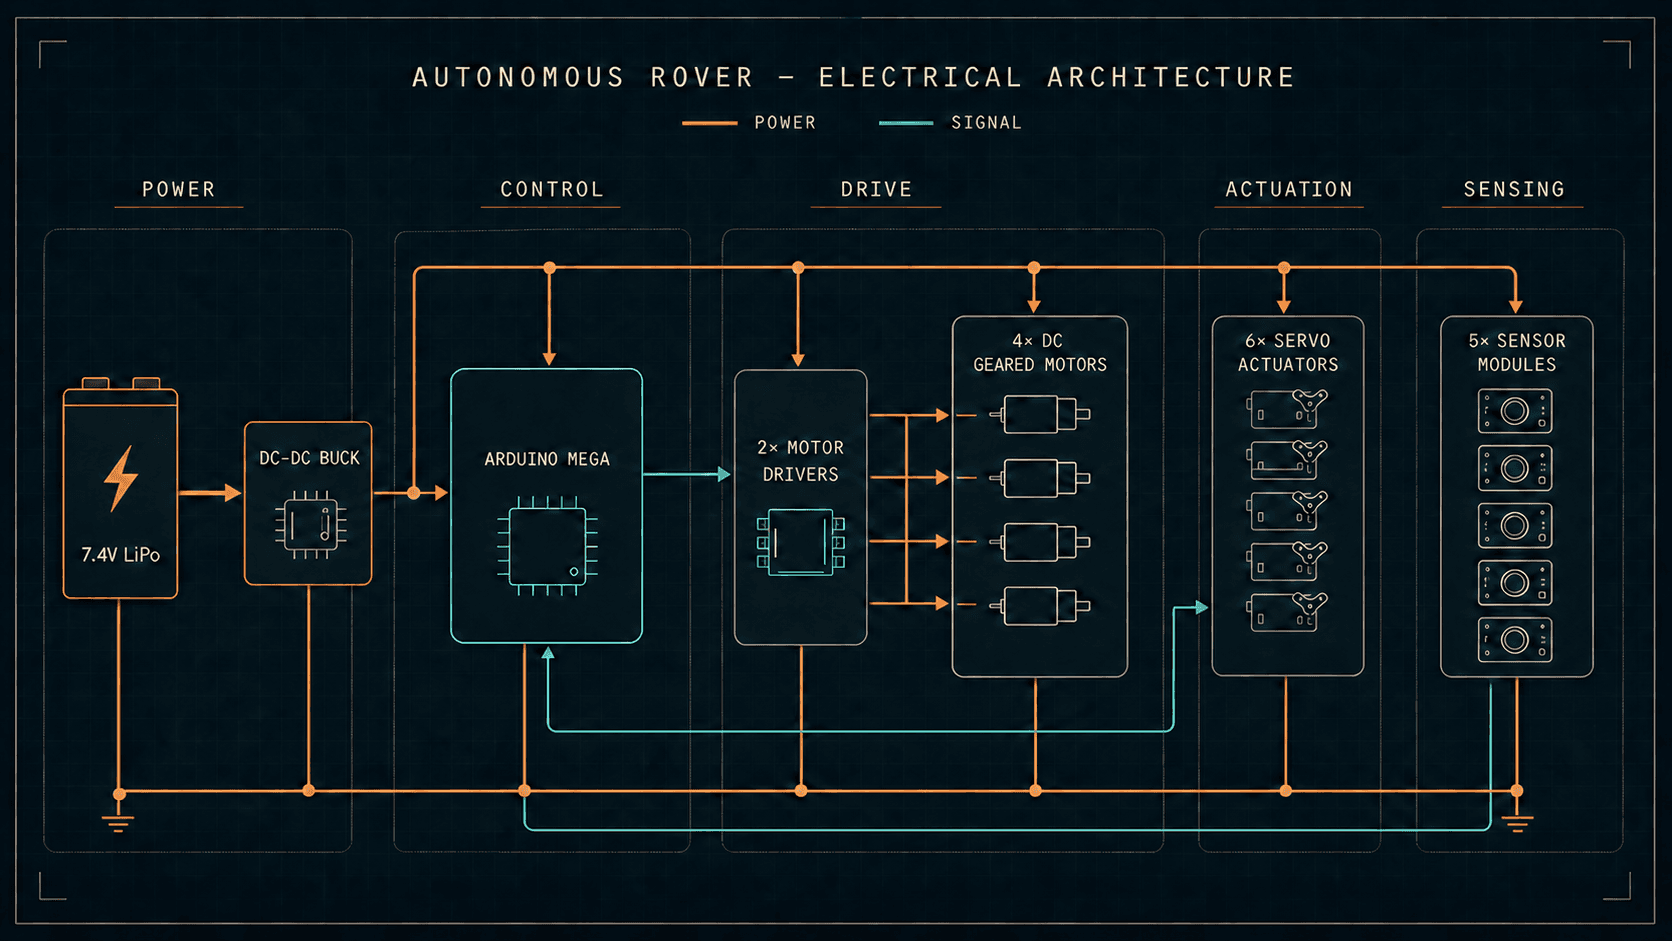
Autonomous rover electrical architecture diagram showing power distribution, the Arduino Mega control board, motor drivers, drive motors, servo actuators, and sensor modules
01

Overview

A three-person capstone project spanning two mission phases: a 4WD skid-steer rover that crosses varied terrain, descends a ramp, delivers a package into a tray, retrieves a second package, and returns — guided by four Time-of-Flight sensors and a 6-DOF IMU on an Arduino Due control stack.

02

Team Project & My Contribution

This was a three-person capstone project built across two development phases. Mechanical design — the chassis, gripper, and drivetrain mounts — was a team effort in CAD and DFM review. My work focused on electrical system integration, embedded software, and the control and sensor-related software running on the rover.

  • Electrical system integration: wiring the Arduino Due, dual TB6612 H-bridge motor drivers, encoder motors, servos, four VL53L1X ToF sensors, and the 6-DOF IMU.
  • Embedded software: the zone-based state machine (Navigate → Deliver → Navigate → Retrieve → Return) and its state re-entry and timeout-recovery logic.
  • Sensor and control software: sequential I2C polling and median filtering across the four ToF sensors, IMU-based heading correction, and encoder-feedback control for wall-following and ramp traversal.
03

System Architecture

Arduino Due

Primary control hardware

Dual TB6612 H-Bridge Drivers

Motor drive interface

4× Micro Gear Encoder Motors (150:1)

4WD skid-steer drivetrain with feedback

Metal-Gear Servos

Gripper actuation, upgraded from SG90 servos after Phase B

Four VL53L1X ToF Sensors

Sequential I2C ranging with median filtering

6-DOF IMU

Heading correction and ramp-tilt monitoring

Custom PLA Chassis (15% infill)

Three-level structure, team CAD design, ~1.5 kg final mass

04

Software / Controls

The rover ran a hierarchical state machine across four zones — terrain navigation, ramp descent, maze delivery/retrieval, and return. Sequential I2C polling and median filtering stabilized the four ToF sensors on uneven terrain, while IMU feedback corrected heading after obstacle avoidance and during ramp climbs. State re-entry logic and timeout-based fallbacks were added after Phase B testing showed the rover could lose track of its position following a manual save-move.

05

Testing

  • Staged testing in three steps: individual sensor/subsystem checks, obstacle-avoidance trials, then full-mission runs varying starting angle, lighting, and obstacle placement.
  • Terrain navigation and obstacle avoidance performed consistently — the rover crossed the terrain zone without drifting.
  • Ramp descent was stable and repeatable, confirming the IMU-assisted ramp-traversal logic carried over correctly from the previous phase.
  • Drivetrain load testing showed stable electrical operation with no excessive heat or current draw; the theoretical torque margin for the 30° incline was not validated as a full climb during final testing.
06

Engineering Challenges

Multi-Sensor Integration

Sequential I2C polling across four ToF sensors to avoid crosstalk on uneven terrain.

Rigid Drivetrain Mounting

Replaced a brass-coupler wheel mount with a direct-screw connection to eliminate slip and improve encoder-based odometry.

State-Machine Recovery

Added re-entry conditions so the state machine could recover position after a manual save-move, addressing a desynchronization issue from the prior test phase.

07

Failure Analysis

The final mission run did not complete the full delivery-and-retrieval sequence, and the causes were mechanical and navigational rather than software:

  • Gripper: two hinge supports were missing from the arm assembly, so it lacked the rigidity to grip the package — a structural build gap, not a servo or control-logic fault.
  • Terrain transition: the rover's wheels caught in the gap between the terrain section and an adjoining metal plate, requiring three manual save-moves to free it.
  • State-machine desynchronization: those save-moves shifted the rover's position enough that its sensor readings no longer matched its expected state, and the state machine halted as a safety fallback before reaching the maze.
  • What did work: sensor initialization, terrain-zone obstacle avoidance, and both ramp descents completed reliably, and FMEA had already flagged navigation, sensor initialization, and drivetrain activation as the highest-risk areas going in.